012024–26
Robots that learn from a single demonstration
A compact dexterous policy that can adapt after one human example.
RoboticsImitation learning
About
My group studies how robots can acquire useful behavior from a handful of human demonstrations. We combine tactile sensing and human-centered evaluation.
Featured research
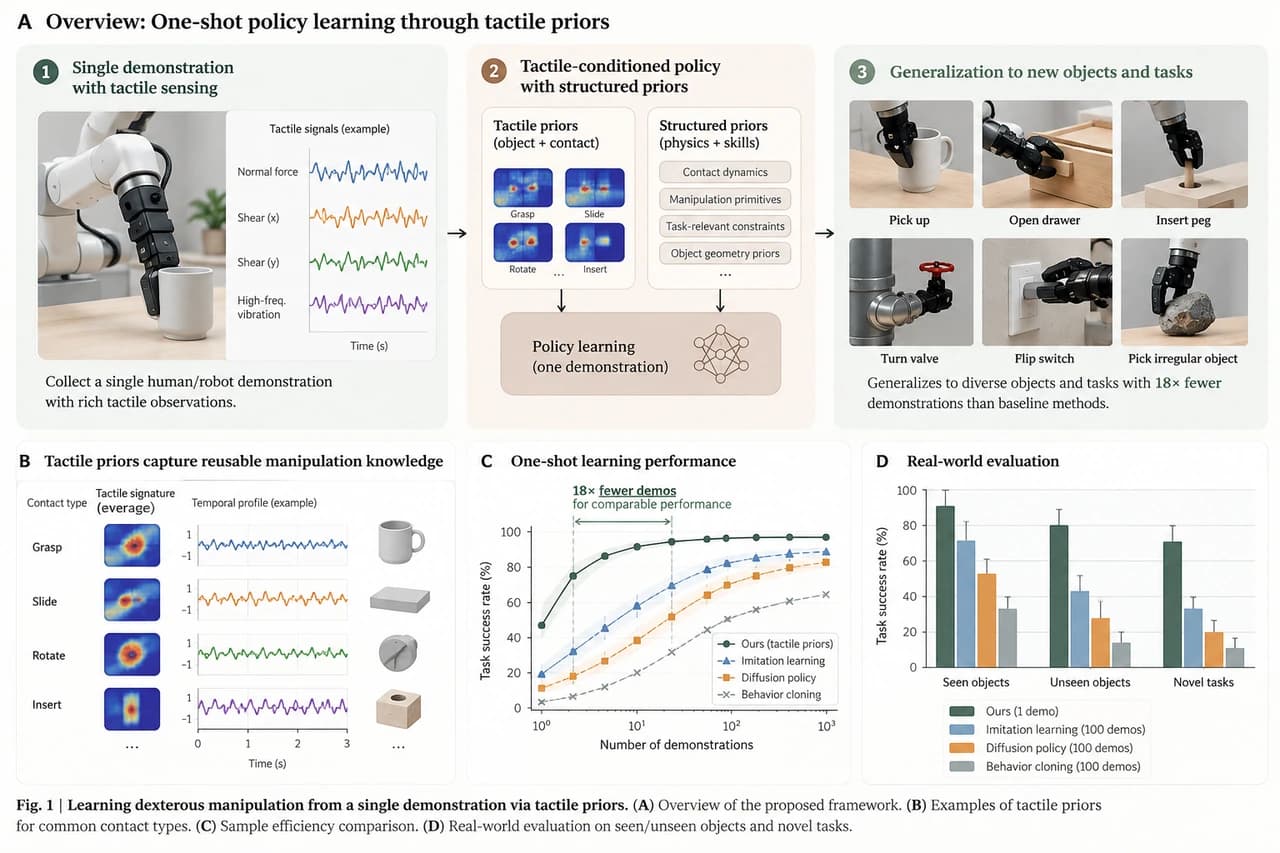
A compact dexterous policy that can adapt after one human example.
Publications
RSS · 2026
FeaturedM. Patel, J. Kim, A. Rodriguez
A tactile prior reduces the demonstration data needed for dexterous policy learning.